Inverse matrices
Lecture 7
Recap
$$ % Colors
% Coordinate vectors and matrices
% Common sets
% Abstract vector symbols
% Norms / absolute value
% Optional: dot product spacing (looks nicer in slides)
% Operators $$
Solving linear equations
- A linear equation has the form \(A\vec{x}=\vec{b}\), where \(A\) is an \(n\times m\) matrix, \(\vec{x}\in\mathbb{R}^m\) is the vector of unknowns, and \(\vec{b}\in\mathbb{R}^n\) is the given vector.
- The corresponding augmented matrix is written as \([A\mid\vec{b}]\).
- To solve a system of linear equations, we apply Gauss–Jordan elimination to the augmented matrix using elementary row operations to obtain the reduced row-echelon form (RREF).
- Depending on the final RREF, the system may have a unique solution, infinitely many solutions, or no solution.
Example 1
Consider the system of linear equations \[ \left\{\begin{aligned} x+2y+3z &= 9\\ 2x-y+z &= 8\\ 3x-z &= 3 \end{aligned}\right. \]
- Write the associated augmented matrix.
- Reduce it to reduced row-echelon form using Gauss–Jordan elimination.
- Solve the system.
- How many solutions are there?
(Submit your answer to iClicker.)

Scan the QR code or go to join.iclicker.com/MBNJ.
Note: If you are completely lost or encounter difficulties, briefly explain your situation instead.
Example 2
Consider the augmented matrix \[ \left[\begin{array}{ccc|c} 1 & 3 & 1 & 0\\ 0 & 0 & 1 & 2\\ 0 & 0 & 0 & 0 \end{array}\right]. \]
- Is this matrix in reduced row-echelon form? If not, reduce it.
- Let the variables be \(x,y,z\). Solve the corresponding system.
- How many solutions are there?
(Submit your answer to iClicker.)
Scan the QR code or go to join.iclicker.com/MBNJ.
Note: If you are completely lost or encounter difficulties, briefly explain your situation instead.
Inverse matrices
Review: linear transformations on \(\mathbb{R}^2\)
- Recall that a linear transformation \(A:\mathbb{R}^2\to\mathbb{R}^2\) describes how points in the plane are deformed linearly.
- If \(\vec{v}_1=A\vec{e}_1\) and \(\vec{v}_2=A\vec{e}_2\), then a vector \[\vec{x}=\langle x_1,x_2 \rangle=x_1\vec{e}_1+x_2\vec{e}_2\] is mapped to \[\vec{y}=A\vec{x}=x_1\vec{v}_1+x_2\vec{v}_2.\]
- Geometrically, \(A\) is completely determined by how the unit square spanned by \(\vec{e}_1,\vec{e}_2\) is transformed into the parallelogram spanned by \(\vec{v}_1,\vec{v}_2\).
Visualizing linear transformations
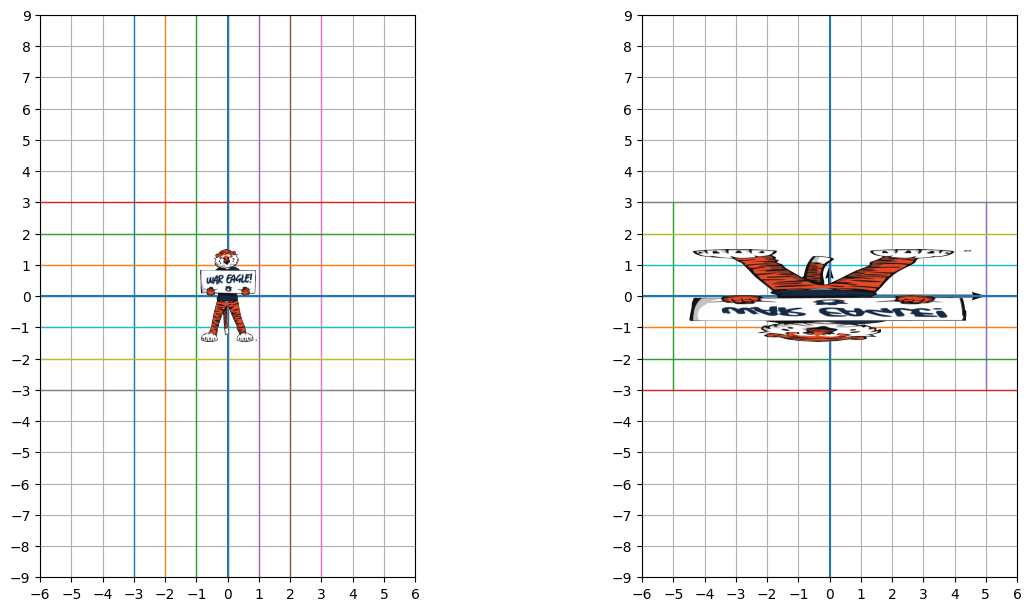
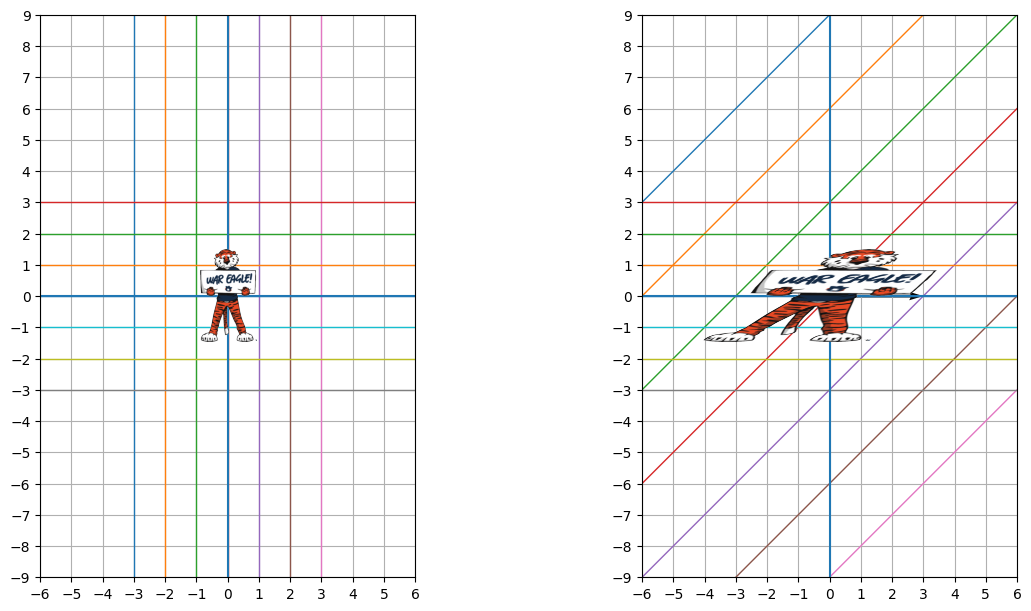
- Each coordinate vector defines an axis, and together they generate a grid on the plane.
- The deformed picture can be understood by tracking how this grid changes. For example, Aubie’s head is located at \((0,1)\) in every coordinate system.
Undo a linear transformation
- Since a linear transformation is determined by how it transforms the grid of unit squares, we may ask whether there exists a linear transformation \[B:\mathbb{R}^2\to\mathbb{R}^2\] that maps the parallelogram spanned by \(\vec{v}_1,\vec{v}_2\) back to the unit square spanned by \(\vec{e}_1,\vec{e}_2\).
- Such a transformation \(B\) would undo the effect of \(A\), and vice versa.
- In other words, for any vector \(\vec{x}, \vec{y}\in \mathbb{R}^2\), \[\vec{x}=B(A(\vec{x})) = B\circ A (\vec{x}),\] \[\vec{y}=A(B(\vec{y})) = A\circ B (\vec{y}).\]
Matrix multiplication as composition
- Consider two linear transformations \(A,B:\mathbb{R}^n\to\mathbb{R}^n\).
- They are represented by matrices \[A=[\vec{a}_1\ \vec{a}_2\ \dots \ \vec{a}_n],\qquad B=[\vec{b}_1\ \vec{b}_2\ \dots \ \vec{b}_n].\]
- Fact: the composition \(C = A\circ B\), read as “apply \(B\) first, then apply \(A\)”, is also a linear transformation.
- How can we represent the matrix of the linear transformation \(C\)?
Matrix multiplication as composition
- The matrix \(C = [\vec{c}_1\ \vec{c}_2\ \dots \ \vec{c}_n]\) is determined by how it acts on the coordinate vectors \(\vec{e}_i\).
- Observe that \[\vec{c}_i = C\vec{e}_i = A(B\vec{e}_i)=A \vec{b}_i.\]
- This is exactly how we defined the matrix multiplication \(AB\).
- Hence, the matrix representing \(A\circ B\) is the matrix product \(AB\).
- Similarly, the composition \(B\circ A\) is represented by the matrix \(BA\).
Inverse matrix
- Let \(A:\mathbb{R}^n \to \mathbb{R}^n\) be a linear transformation.
- If another linear transformation \(B:\mathbb{R}^n \to \mathbb{R}^n\) undoes what \(A\) does (and vice versa), then \[AB=BA=I_n,\] where \(I_n\) is the \(n \times n\) identity matrix.
- Fact: if such a matrix \(B\) exists, it is unique, and \(A\) is called invertible.
- This matrix \(B\) is called the inverse matrix of \(A\), denoted by \(A^{-1}\).
Relation to linear equations
- Suppose we want to solve the linear equation \[A\vec{x}=\vec{b}.\]
- If \(A\) has an inverse matrix, we can “undo” \(A\) by multiplying both sides by \(A^{-1}\): \[\vec{x}=A^{-1}A\vec{x}=A^{-1}\vec{b}.\]
- This produces a single vector solution, so the solution is unique.
- Therefore, a matrix \(A\) has an inverse if and only if it can be reduced to the identity matrix \(I_n\) using elementary row operations.
When is a matrix invertible?
- Consider the case where \(A=[\vec{v}_1\ \vec{v}_2]\) is a \(2\times2\) matrix.
- Geometrically, \(A\) transforms the square grid spanned by \(\vec{e}_1\) and \(\vec{e}_2\) into the parallelogram grid spanned by \(\vec{v}_1\) and \(\vec{v}_2\).
- If this parallelogram forms a genuine grid (that is, it has nonzero area), then it can be “unsqueezed” back to the unit square, and the matrix is invertible.
- However, if \(\vec{v}_1\) and \(\vec{v}_2\) collapse into a single line and fail to form a grid, information is lost and the transformation cannot be undone.
For example, this happens when \(\vec{v}_1=c \vec{v}_2\). - This geometric viewpoint motivates the concept of the determinant, which we will study later.
Calculating the inverse matrix
- Computing inverse matrices is an important task in numerical analysis.
- In general, finding inverses can be computationally expensive and numerically sensitive.
- There are several algorithms and approximation methods designed for this purpose.
- In this course, we will not focus on these methods in detail; you may use computer software when needed.
- However, for a \(2\times2\) matrix, there is a simple formula you can verify by hand: \[A^{-1}=\frac{1}{ad-bc}\begin{bmatrix} d & -b \\ -c & a \end{bmatrix}, \qquad \text{when } A=\begin{bmatrix} a & b \\ c & d \end{bmatrix} \text{ and } ad-bc\neq0.\]
Preview
- In the next class, we will interpret elementary row operations as special linear transformations represented by matrices called elementary matrices.
- In fact, we already learned those—scaling, transposing, and shearing.
- Since Gauss–Jordan elimination is a sequence of such operations, it can be written as a product of elementary matrices.
- If a matrix is invertible, Gauss–Jordan elimination reduces it to the identity matrix.
- In this process, we explicitly construct a matrix that multiplies the given matrix to give the identity—that matrix is the inverse.